Halt
HALT — everything breaks eventually. plan what your robot does when it does — fail safe, not dangerous.
Loading audio…
Press play to listen along. The line being read lights up as you go.
Show full transcript
Loading transcript…
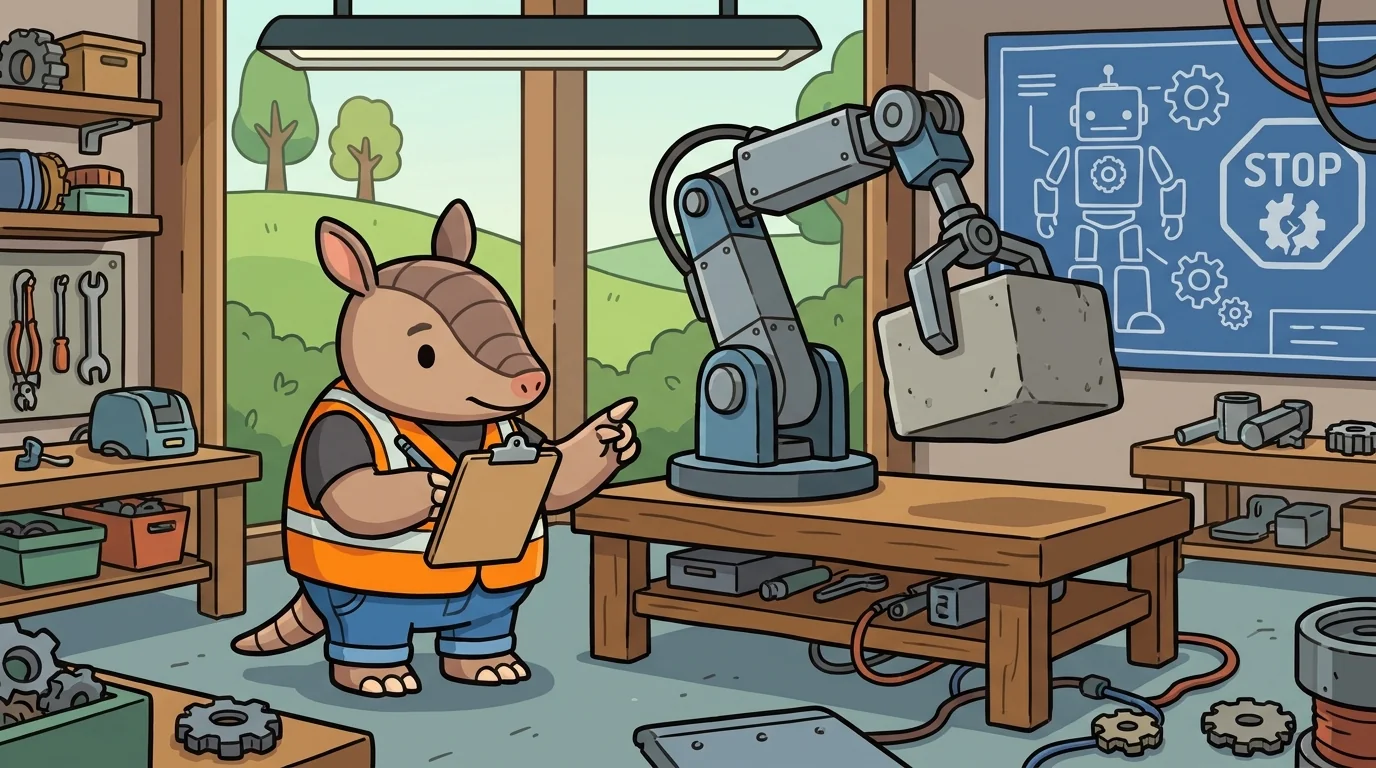
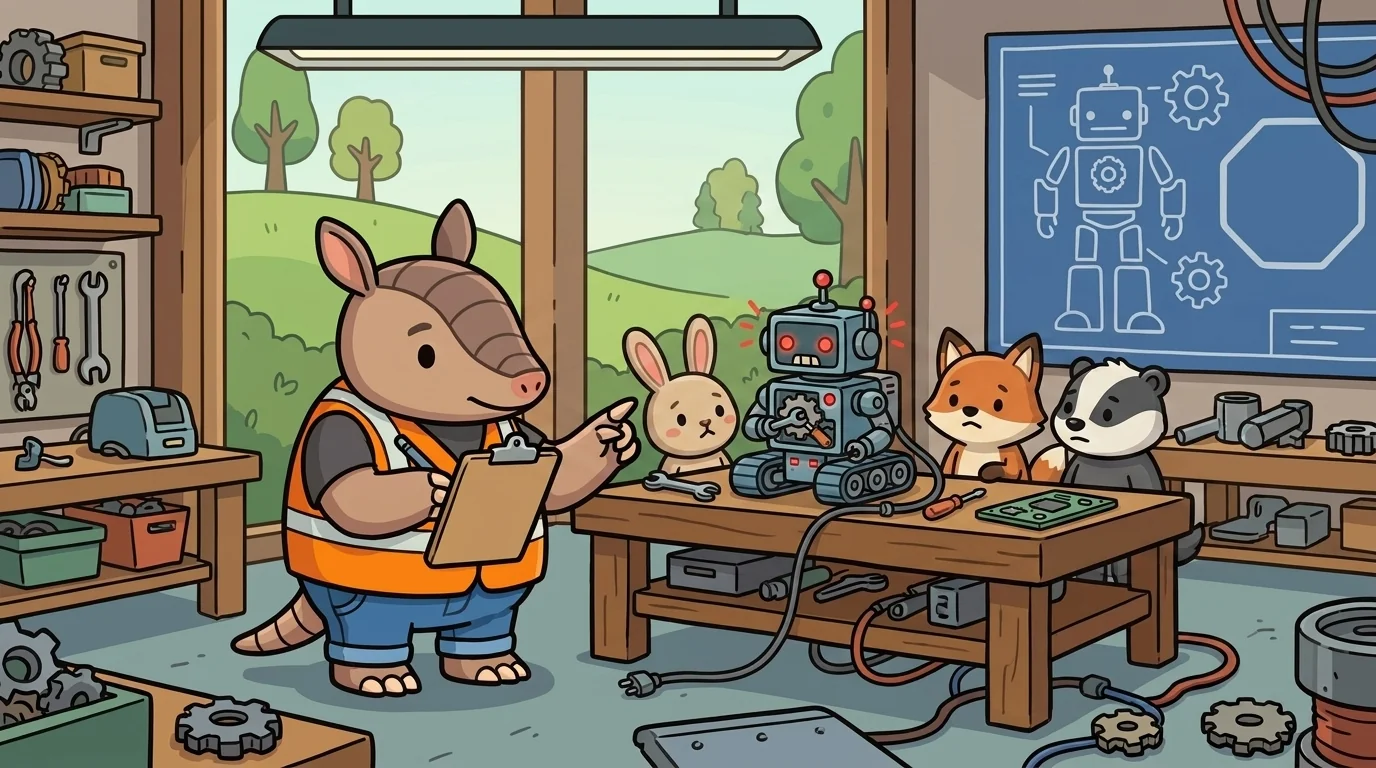
On Halt's workbench a robot arm lifted a heavy block, and Halt — a calm armadillo in a safety-vest — watched not the success but the one question nobody else asked: what happens if this breaks?
"Everyone designs for the robot working," he said, tapping his clipboard. "Almost nobody designs for it breaking. But everything breaks eventually — a motor jams, a wire loosens, a sensor goes dark, the battery sags. Reliability engineering doesn't pretend that won't happen. It asks, for each failure: what does the robot do the moment it does?"
He pointed at the arm. "Say the motor jams while holding this block. A naive robot keeps commanding full torque — grinding, overheating, maybe dropping the block, maybe catching fire. A fail-safe robot detects the fault and moves to a safe state — sets the block down, freezes, powers the motors down harmless. That's the whole discipline: fault detection, then a defined safe response."
He showed the builders three mechanisms. "First, detection: the robot has to know it's broken. So the motor watches its own current — a stalled motor pulls a huge spike, which is the signature of a jam. The sensor loop checks whether readings still make sense. Second, a watchdog timer: a little clock the main program must 'pet' every cycle. If the program hangs and stops petting it, the watchdog fires on its own and forces the robot into safe-state — because a frozen brain can't rescue itself. Third, graceful degradation: when one part fails, the robot doesn't collapse — it drops to a reduced-but-safe mode. Lose a sensor? Slow down, don't guess. Lose half your power? Return home, don't start new work."
He curled a protective paw. "And the golden rule under all of it: fail toward safe. When anything is wrong — stop, slow, park, or power down gently — never grind, force, race, or guess. Add a clear 'I have a problem' signal, a light or a beep, so a human can help; a robot that hides its fault and struggles on is far more dangerous than one that stops and asks."
A student frowned. "Isn't planning for failure kind of giving up before you start?"
"The opposite," said Halt. "Because your robot always fails safely, you're free to try the bold, fast, risky things. You can send it on any wild mission with an easy heart, knowing that if it breaks, it breaks gently. Fail-safe design doesn't make you timid. It makes you brave."
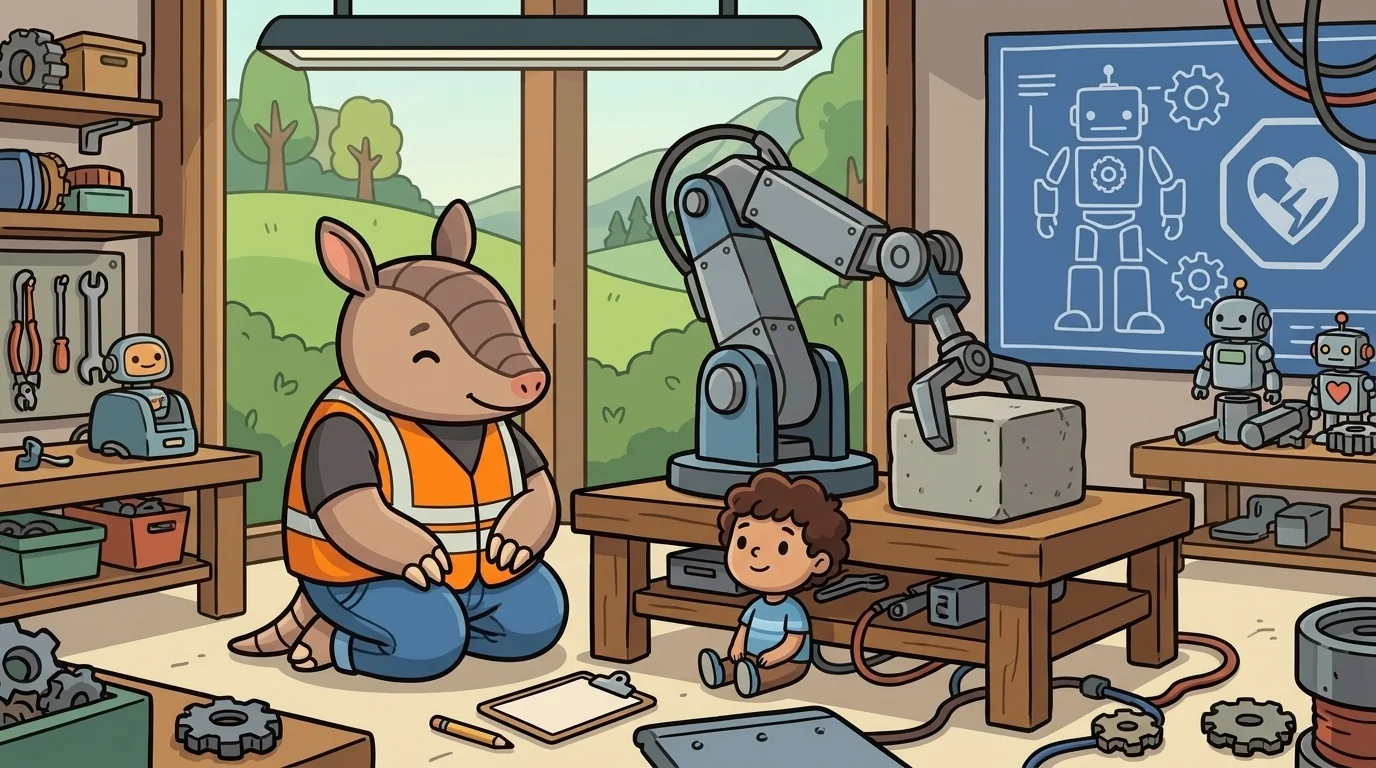
"So planning for the worst is what lets me try the boldest things," the student said slowly.
"Fail safe, and you're free to be brave," Halt agreed, and he settled onto his sturdy haunches beside his always-safe robots. A warm, protected happiness settled in him — the calm of one who had stopped fearing breakdown by planning for it, who knew a robot built to break gently was a robot he could trust anywhere.
His shell rose and fell, slow and easy. "Everything breaks," he said softly. "So decide, now, how it breaks — and then go be as brave as you like."
The RoboForge ensemble
Halt is part of RoboForge's distributed-narrative cast. Each character embodies a different curricular primitive; together they teach the full subject.
-
Bolt
Chassis + mechanical structure — 'the frame holds everything; build the chassis like you mean it'
-
Sense
Sensors + perception — 'the robot only knows what it can sense; choose the senses for the job'
-
Drive
Motors + actuators + movement — 'motors turn power into motion; balance speed and control'
-
Loop
Iteration + sensor-driven control loops — 'read. decide. act. repeat. that's the whole robot brain'
-
Tune
Testing + calibration + iteration — 'first run fails. that's information. tune + run again' (closes cast arc)
-
Charge
Power budget + energy management — 'every part sips power; know your battery budget or your robot dies mid-mission'
-
Clamp
Grippers + manipulation — 'grabbing is harder than it looks; hold firm enough not to drop, gentle enough not to crush'
-
Hail
Communication + signals — 'a robot alone knows only its own corner; robots that talk share what they each can see'
-
Rove
Navigation + pathfinding — 'don't just go toward the goal; find a PATH around what is in the way'